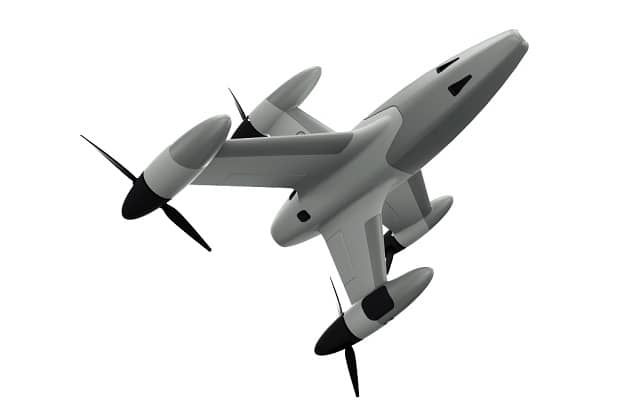
Concept visualizationExperience loading
01 / 04Preparing the experience
Cross-domain robotics R&D

Intelligent machines for complex environments.

Robotics across air, ground and human environments—uniting engineering, perception and control.

Explore a partnership
Mission

Build machines that perceive, decide and move with purpose.

Flight, terrain and human spaces demand different bodies. We study them together while respecting what makes each distinct.

  • 01Perceive clearly
  • 02Decide deliberately
  • 03Move with purpose
Platforms / 03

Aerial. Ground.
Humanoid.

Three research domains, each shaped by its environment and mission.

Concept rendering of an aerial robotic system01 / AerialConcept research

Aerial

Research domain 01
Environment
Elevated and hard-to-reach environments.
Engineering challenge
Navigate changing conditions with resilient perception.
Current research focus
Airframe-aware autonomy and mission planning.
  • Inspection
  • Hazard awareness
  • Defense
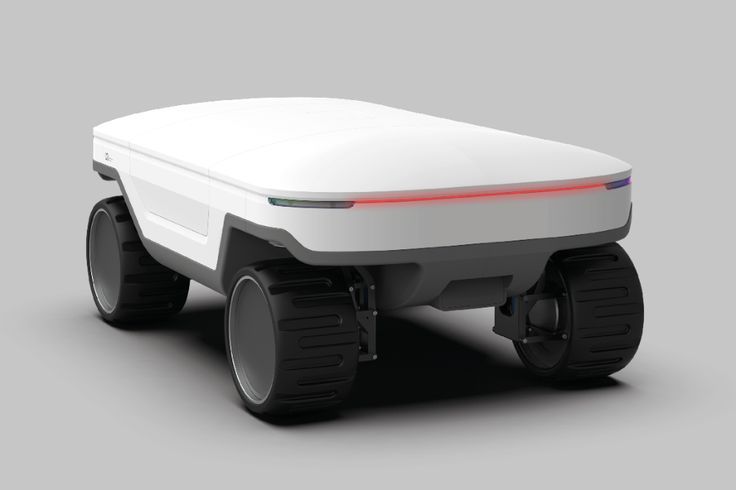
Concept rendering of a ground robotic system02 / GroundConcept research

Ground

Research domain 02
Environment
Unstructured terrain and hazardous sites.
Engineering challenge
Read nearby terrain without losing stability.
Current research focus
Local perception, route planning and mobility.
  • Industry
  • Hazardous access
  • Defense
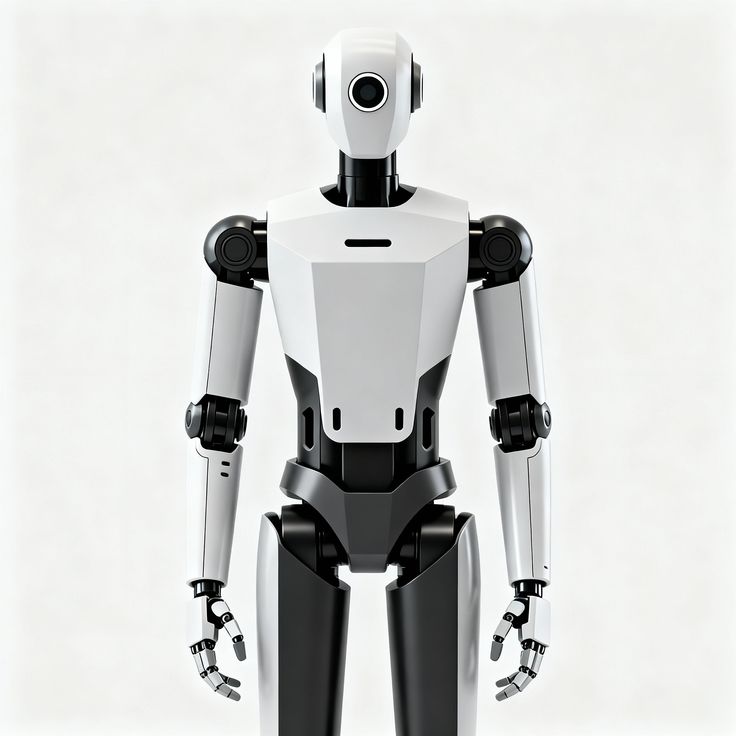
Concept rendering of a humanoid robotic system03 / HumanoidConcept research

Humanoid

Research domain 03
Environment
Human-built spaces, tools and workflows.
Engineering challenge
Balance, manipulate and act as one system.
Current research focus
Whole-body control and task sequencing.
  • Industry
  • Hazardous tasks
  • Human spaces
Shared engineering loop

Autonomy connects every form.

One disciplined loop turns environmental signals into deliberate motion across every platform.

  1. 01

    Sense

    Read the system and its surroundings.

  2. 02

    Model

    Represent state and environment.

  3. 03

    Plan

    Choose the next action.

  4. 04

    Control

    Turn decisions into stable commands.

  5. 05

    Move

    Act and feed the result back.

Applied across:AerialGroundHumanoid
Research in Motion / 05

See the ideas move.

Interactive studies showing engineering intent—not live or deployed systems.

Static fallback for the aerial concept model
Aerial concept studyConcept

Flight form in motion

3D concept model

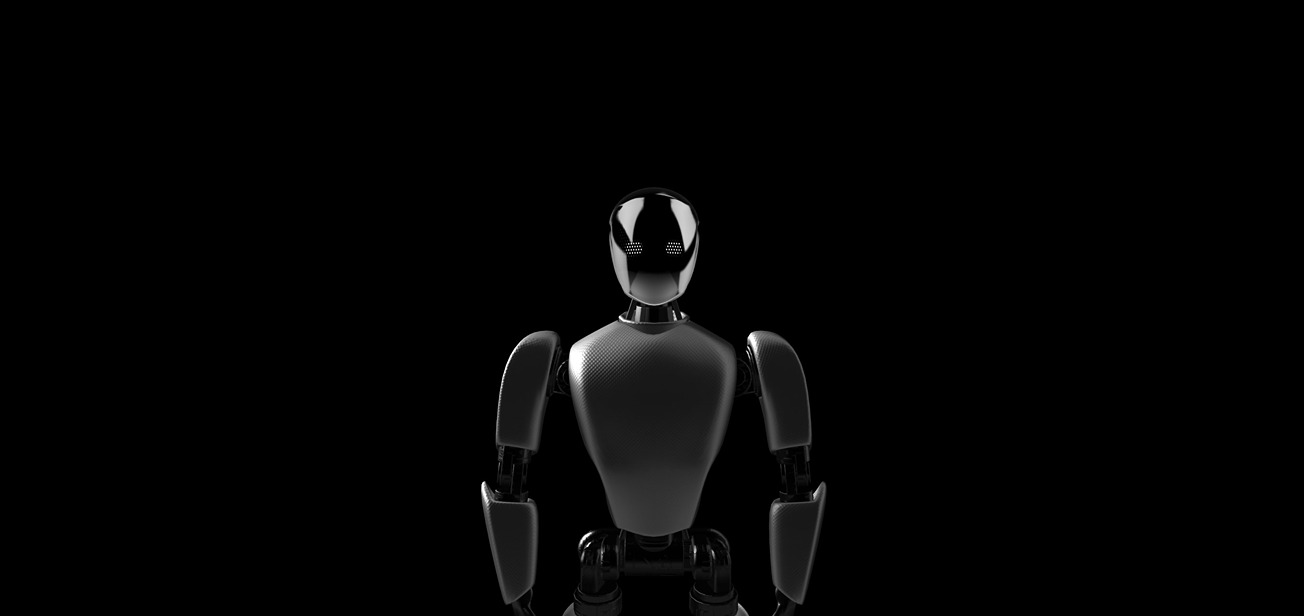
Static fallback for the humanoid concept model
Humanoid concept studyConcept

Embodiment in human spaces